Motion control
Standing, walking, turning, getting up and recovering from pushes.
What matters
T1T2H2 EDUJoint-level access, simulation, and a protective rig for low-level work.


Research
Match your research task to the right platform, edition and toolchain. We confirm software versions and interfaces before you order, then handle sourcing and delivery.
Four directions, and what each asks of a platform. Most projects touch more than one.
Standing, walking, turning, getting up and recovering from pushes.
Joint-level access, simulation, and a protective rig for low-level work.
Recognising objects and people, visual localisation and voice interaction.
Camera access, microphones and enough on-board computing.
Target localisation, hand-eye coordination, grasping and two-handed tasks.
7-DoF arms, a gripper or dexterous hand, and wrist cameras.
Reinforcement and imitation learning in simulation, then transfer to hardware.
Robot models, simulators, external GPUs and a sim-to-real plan.
Four platforms, from developer-led motion work to the full embodied AI workflow. Figures follow the manufacturers’ published tables.
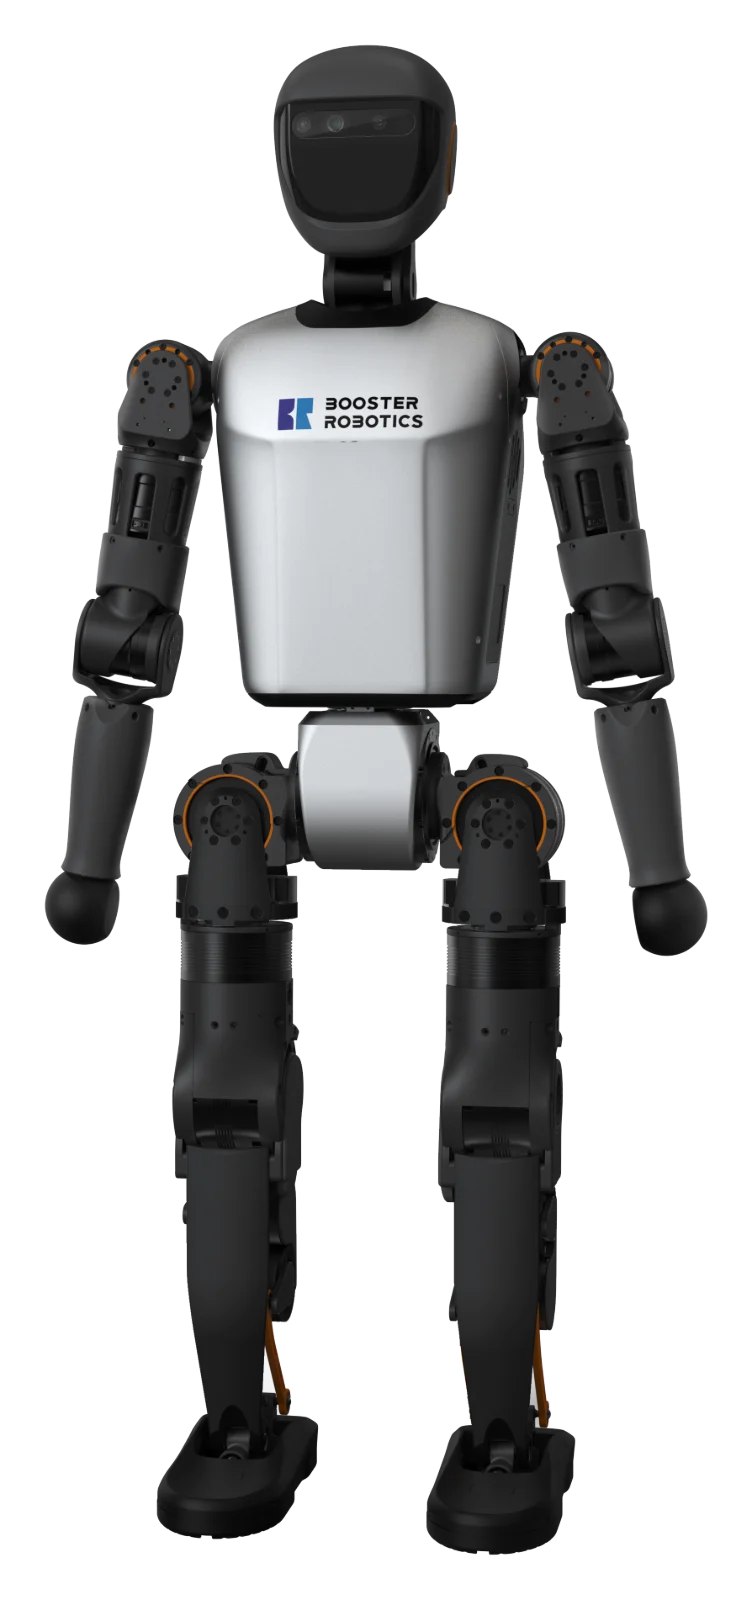
Developer platform for motion control, perception and robot football.
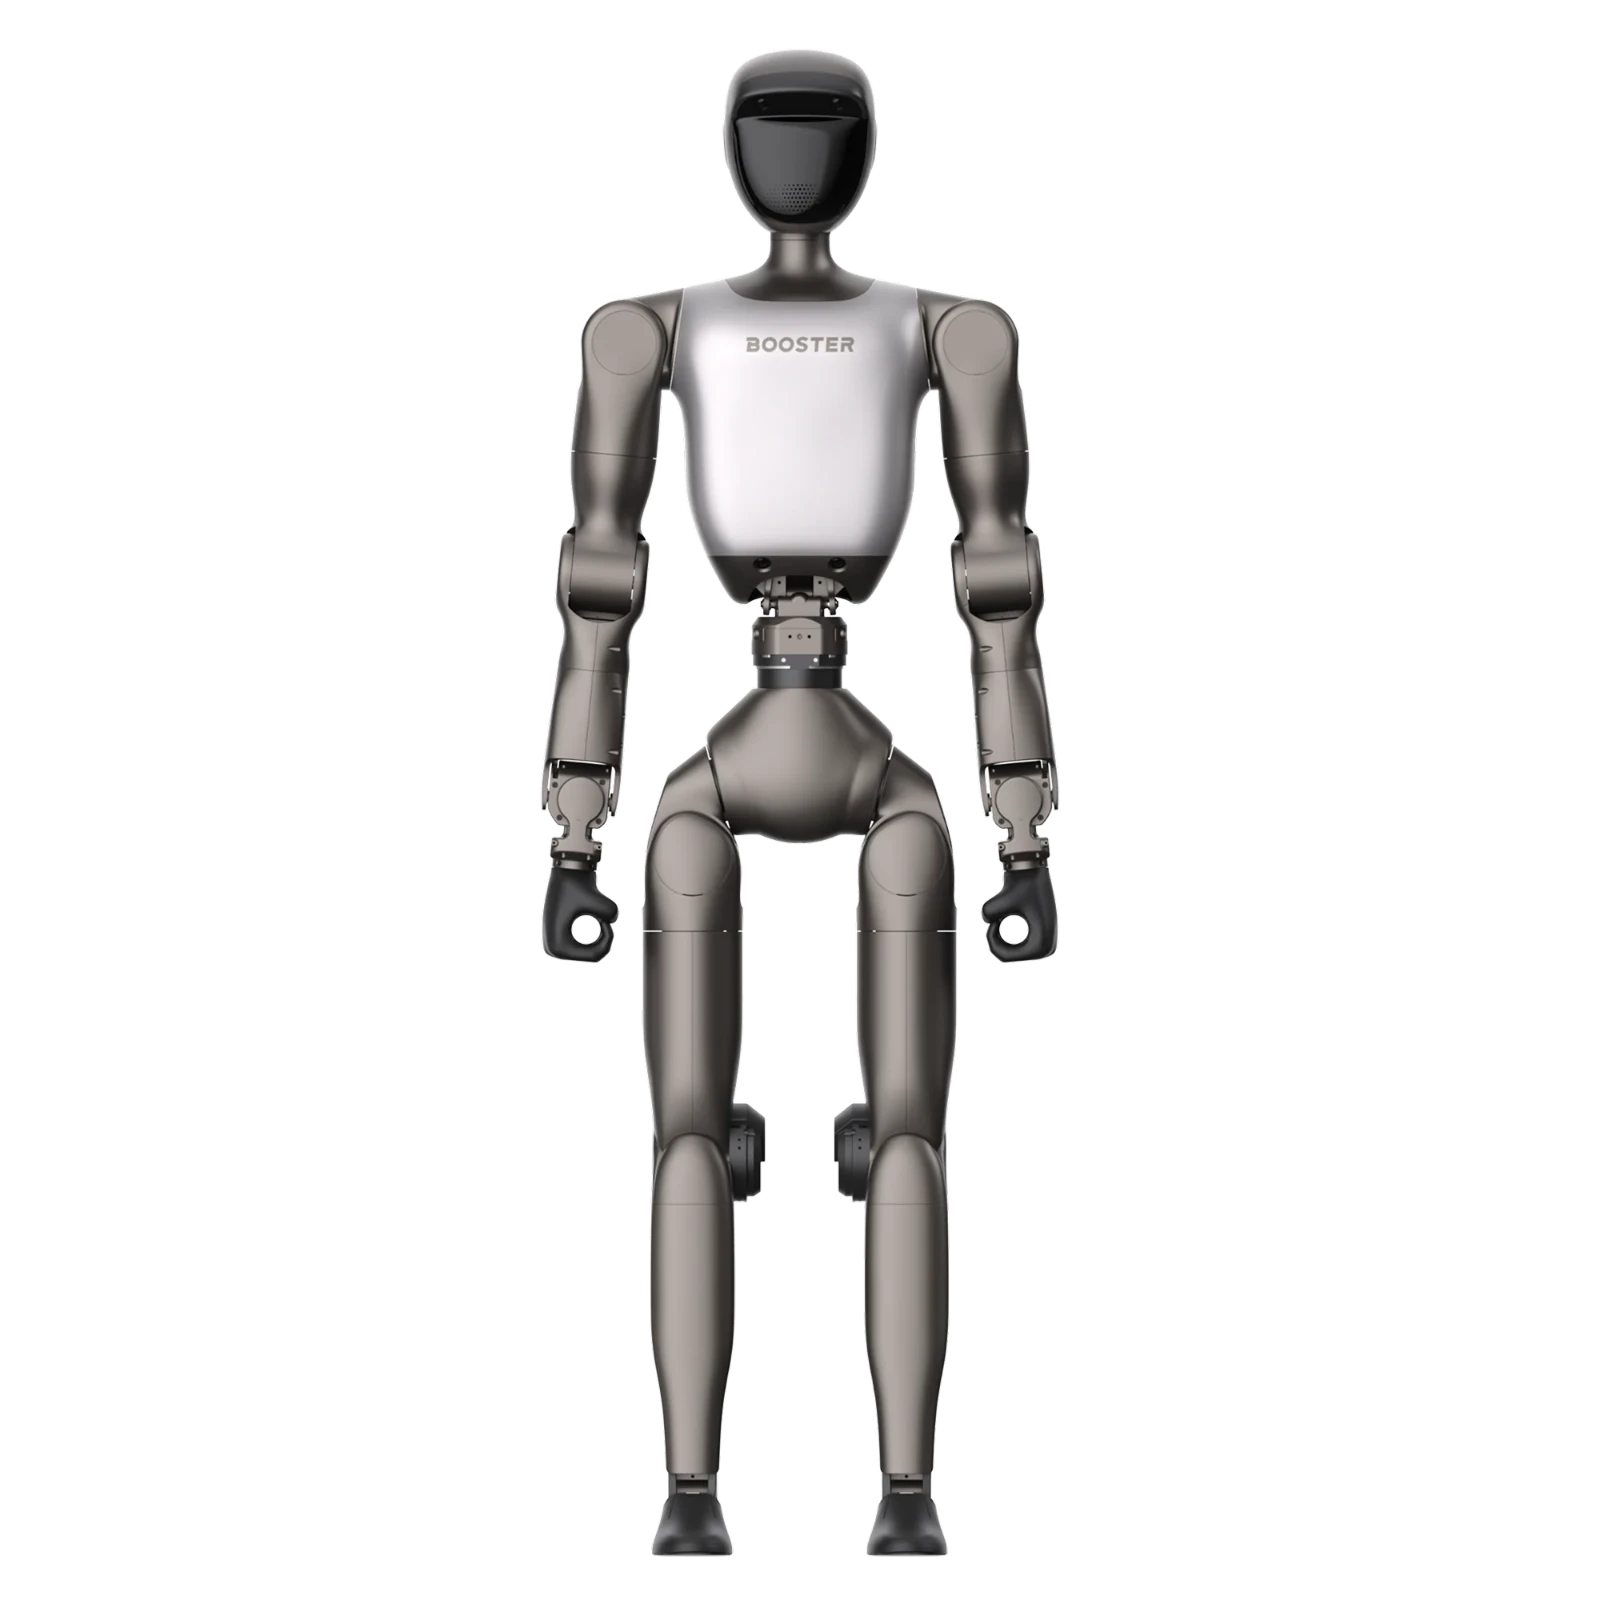
Flagship platform for manipulation and integration research.
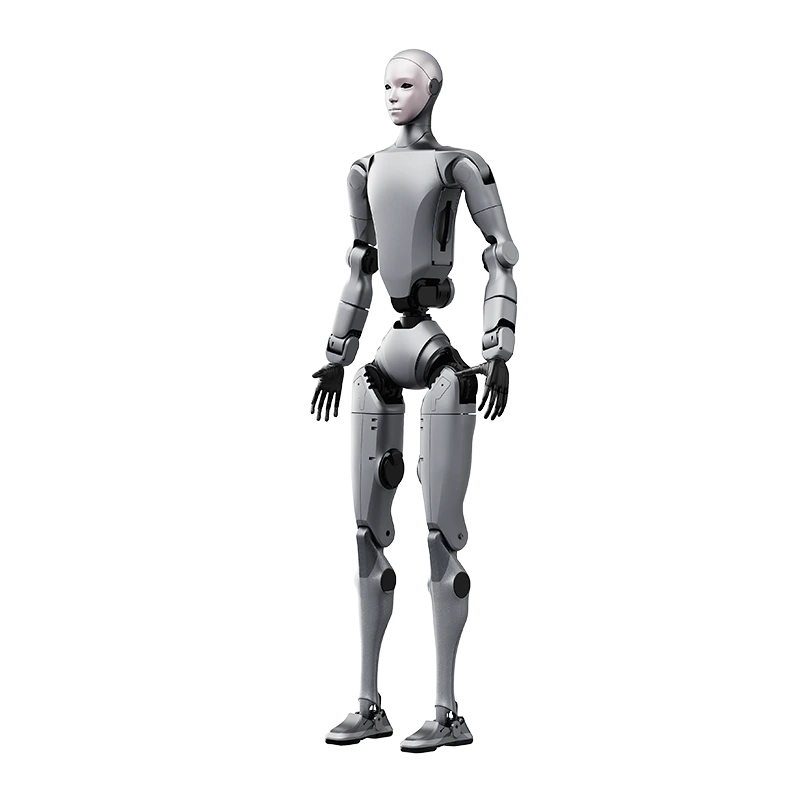
Full-size humanoid; only the EDU edition opens secondary development.
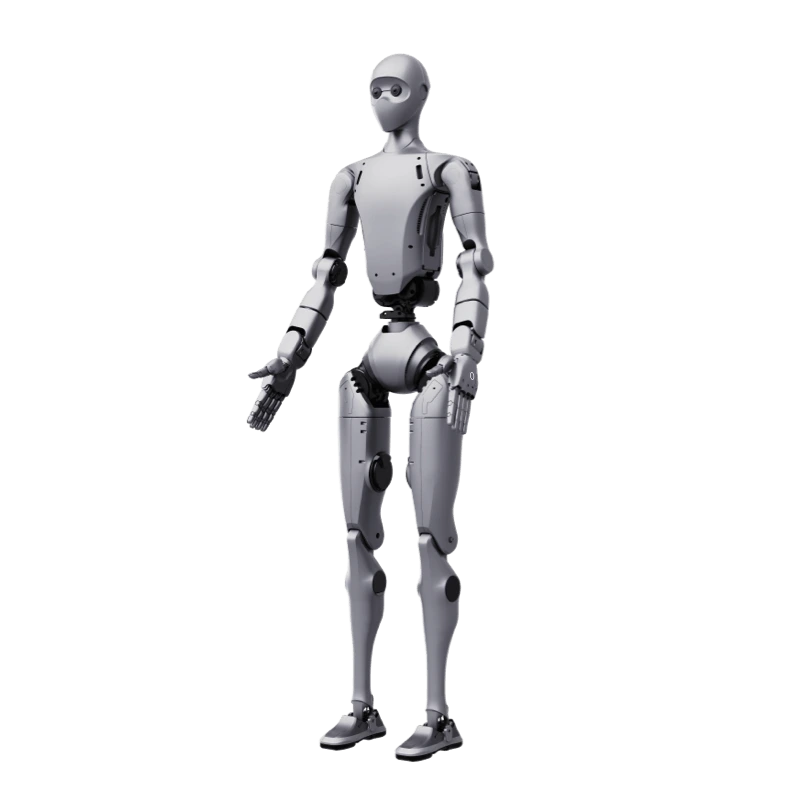
Built for the full embodied AI workflow, from teleoperation to deployment.
Computing figures use different units and precisions, so they are not directly comparable. Optional parts depend on your order; we confirm current availability for each configuration.
A typical embodied AI workflow, with the tools documented for each platform. Each link needs checking on your exact versions.
Record demonstrations by teleoperation: camera images, joint states and actions.
xr_teleoperate · Isaac TeleOpTest motions and agents in a virtual environment before using hardware.
Booster Studio · MuJoCo · Isaac SimTrain policies with reinforcement or imitation learning, on your own GPU workstation.
unitree_rl_gym · Isaac Lab · LeRobotRun the policy on a protected robot, then measure the sim-to-real gap.
SDK · ROS 2 · JetsonWe record firmware, SDK and ROS 2 versions with your order, and check each repository’s supported robots against your configuration.
An operator guides the robot; the recording becomes training data. Every step from headset to policy needs testing on your setup.
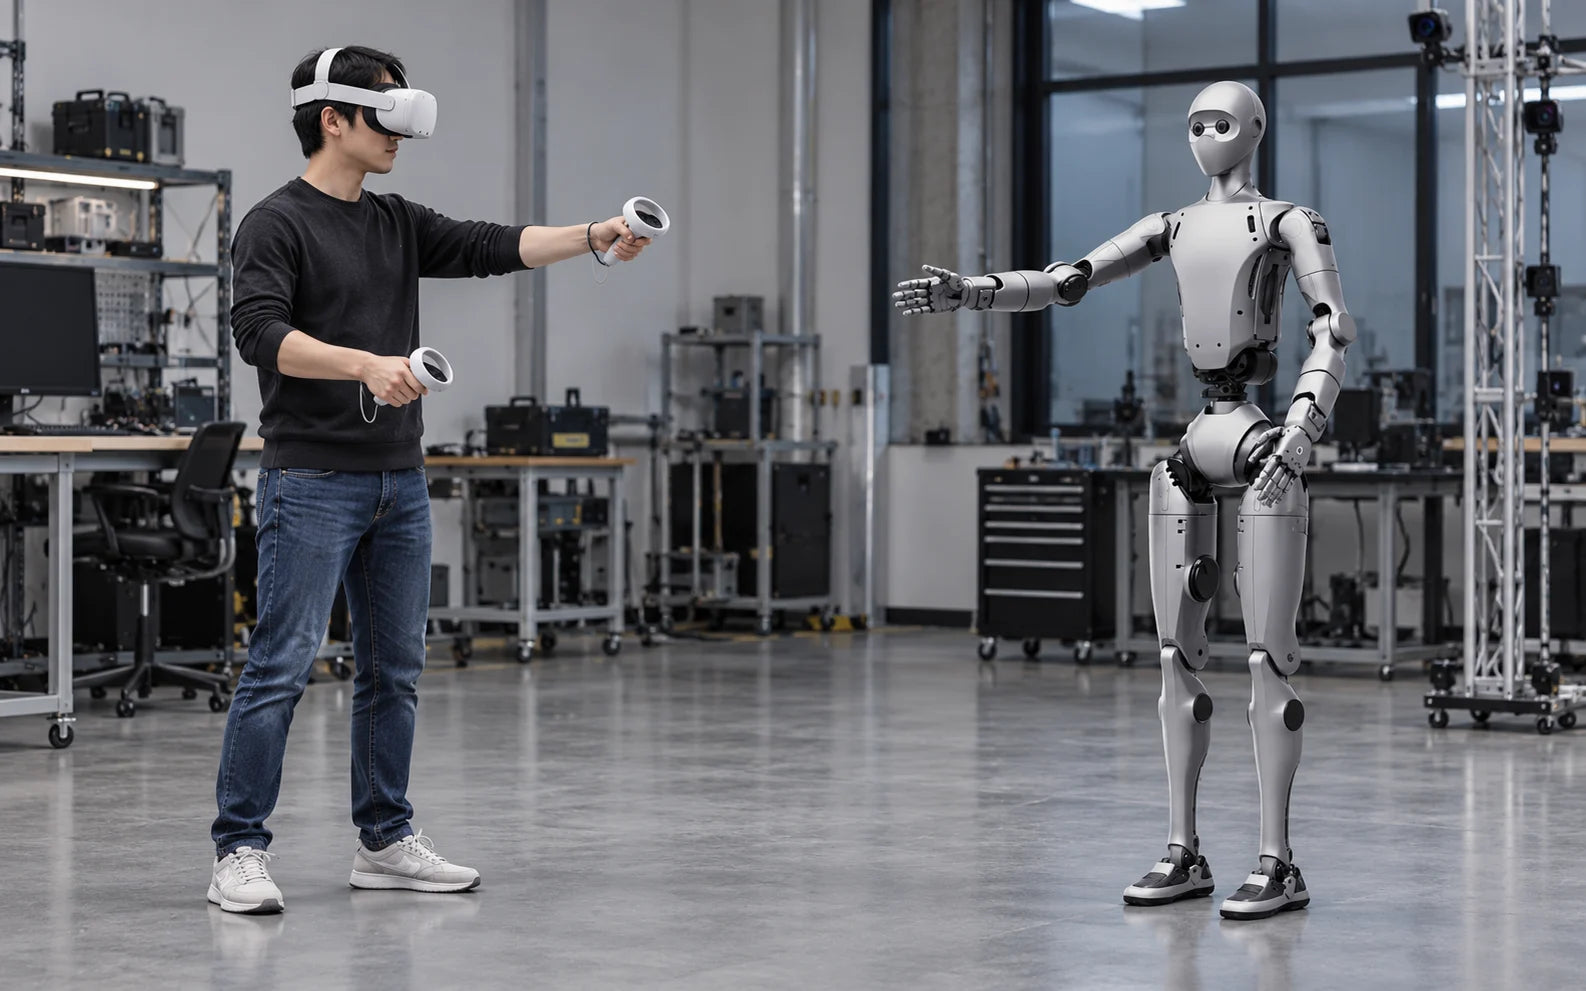
Unitree’s xr_teleoperate supports Apple Vision Pro, PICO 4 Ultra Enterprise and Meta Quest 3, including H2 with 7-DoF arms. H2 Plus isn’t on that list; its page lists Isaac TeleOp.
H2H2 Plus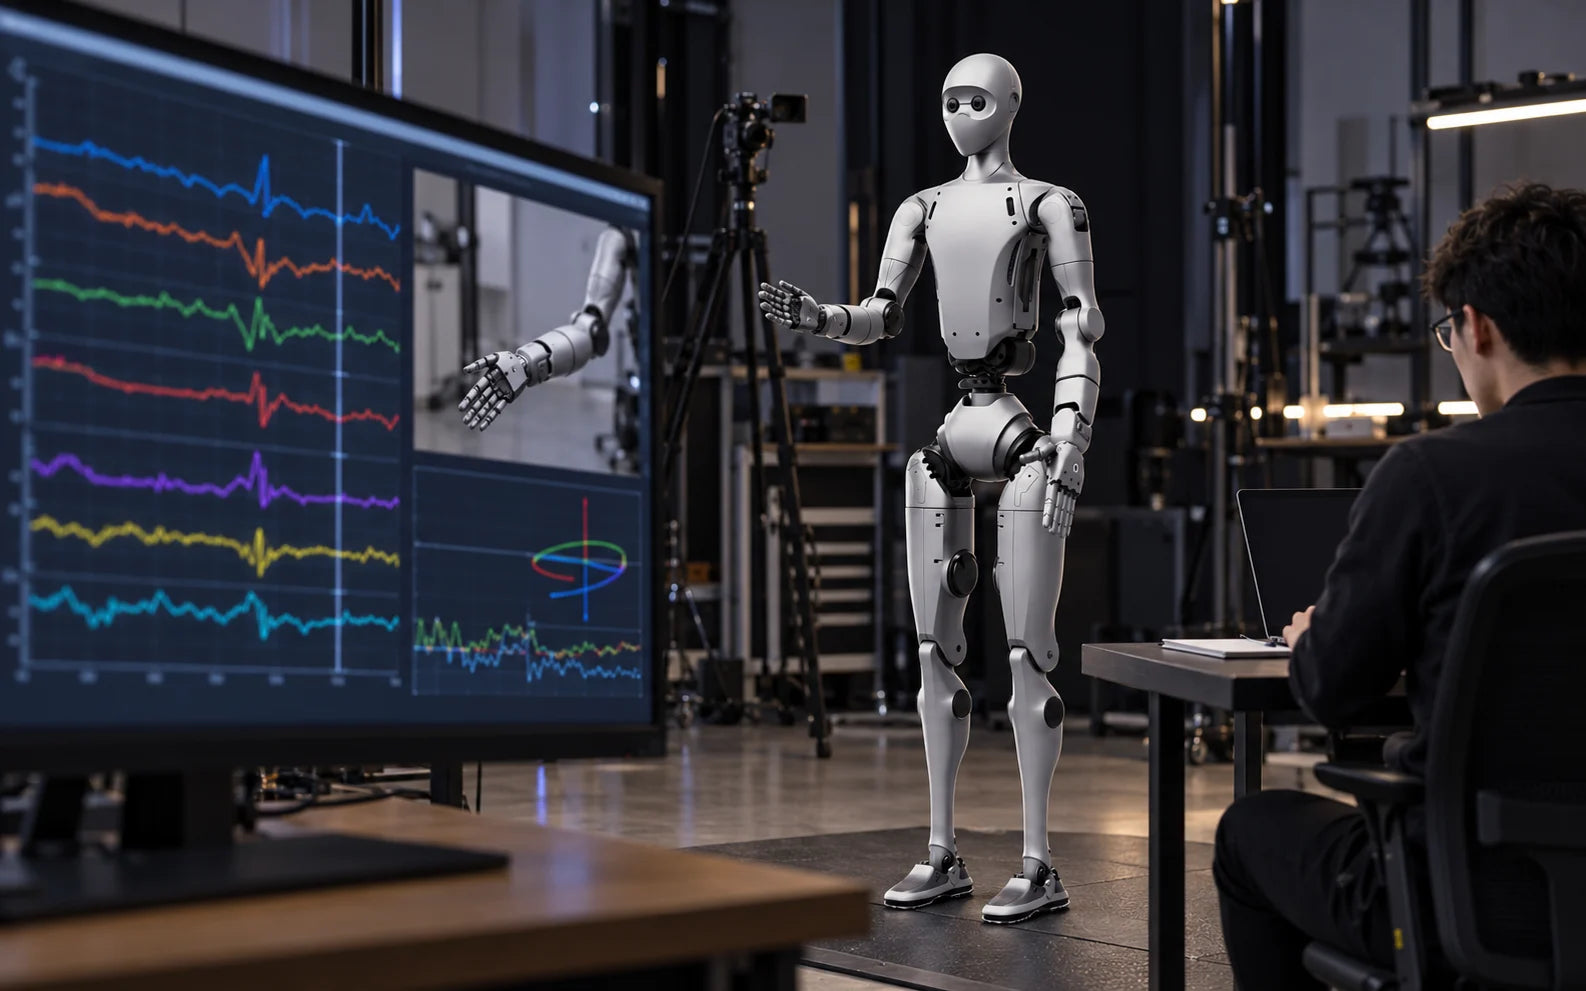
unitree_lerobot converts and replays recordings in LeRobot v3 format for training. Before you rely on it, we suggest a short test: record, convert, train and replay on your exact configuration.
H2H2 PlusImages in this section are illustrations, not photographs of a specific setup.
Demonstrations show what a platform can be used for, not what ships in the box. Here is what each one still needs.
Two-handed work on H2 Plus. Hands and wrist cameras are optional, and some functions are still in development.
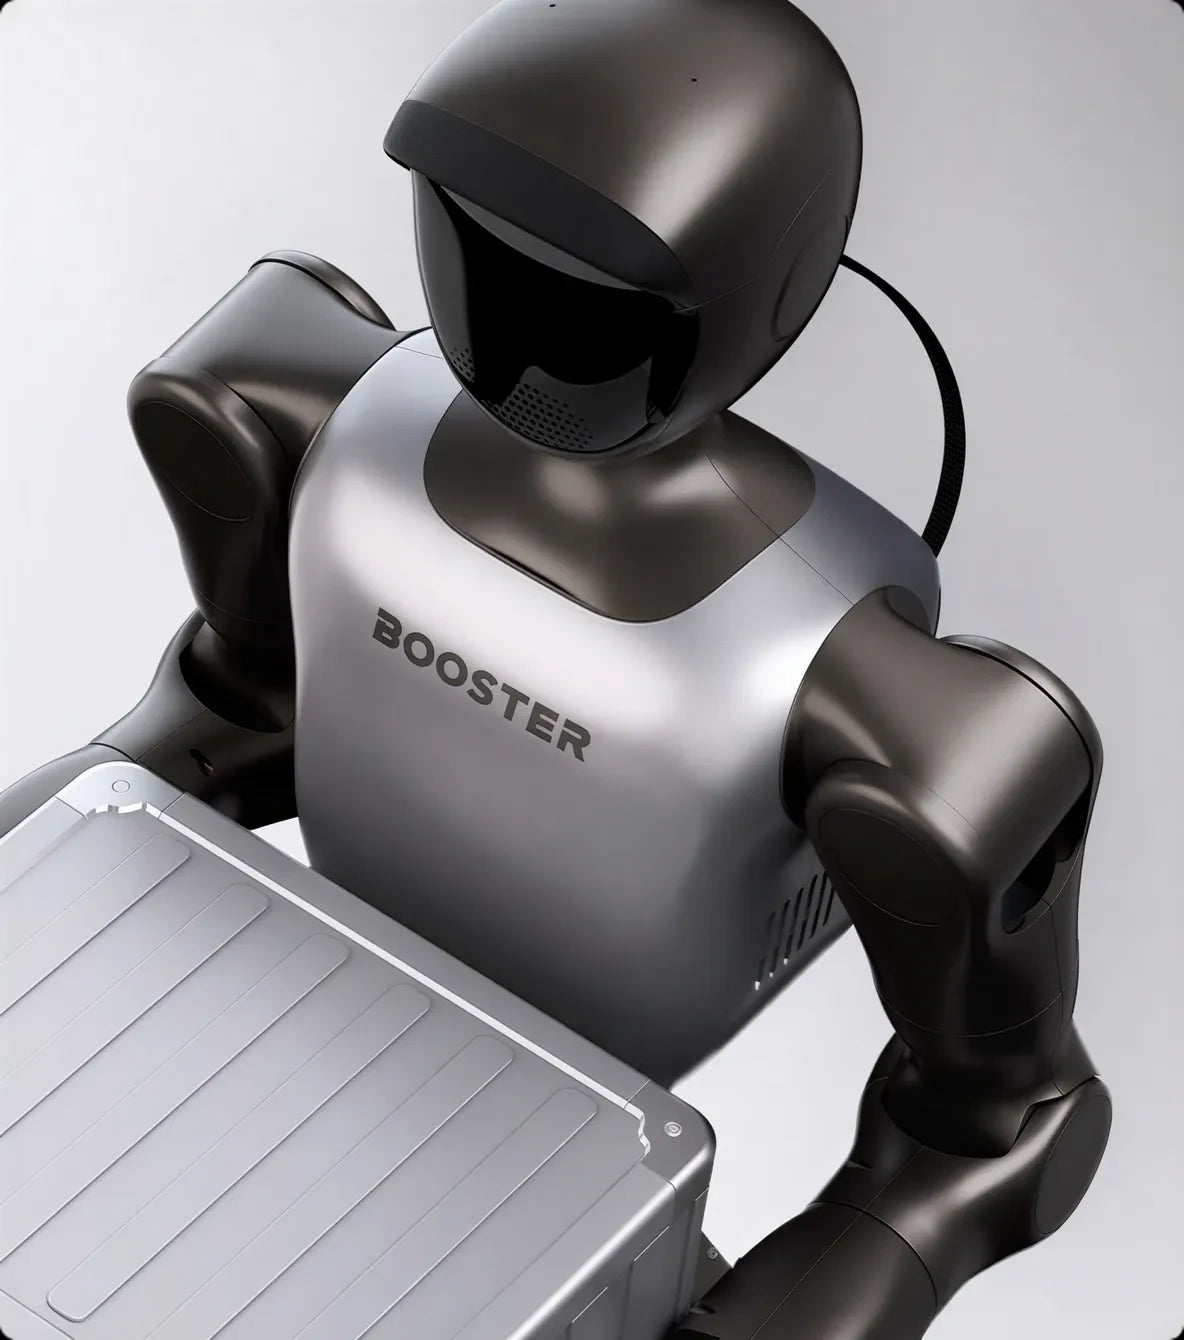
Picking up and moving boxes. A real task needs your data, a trained policy and testing on site.
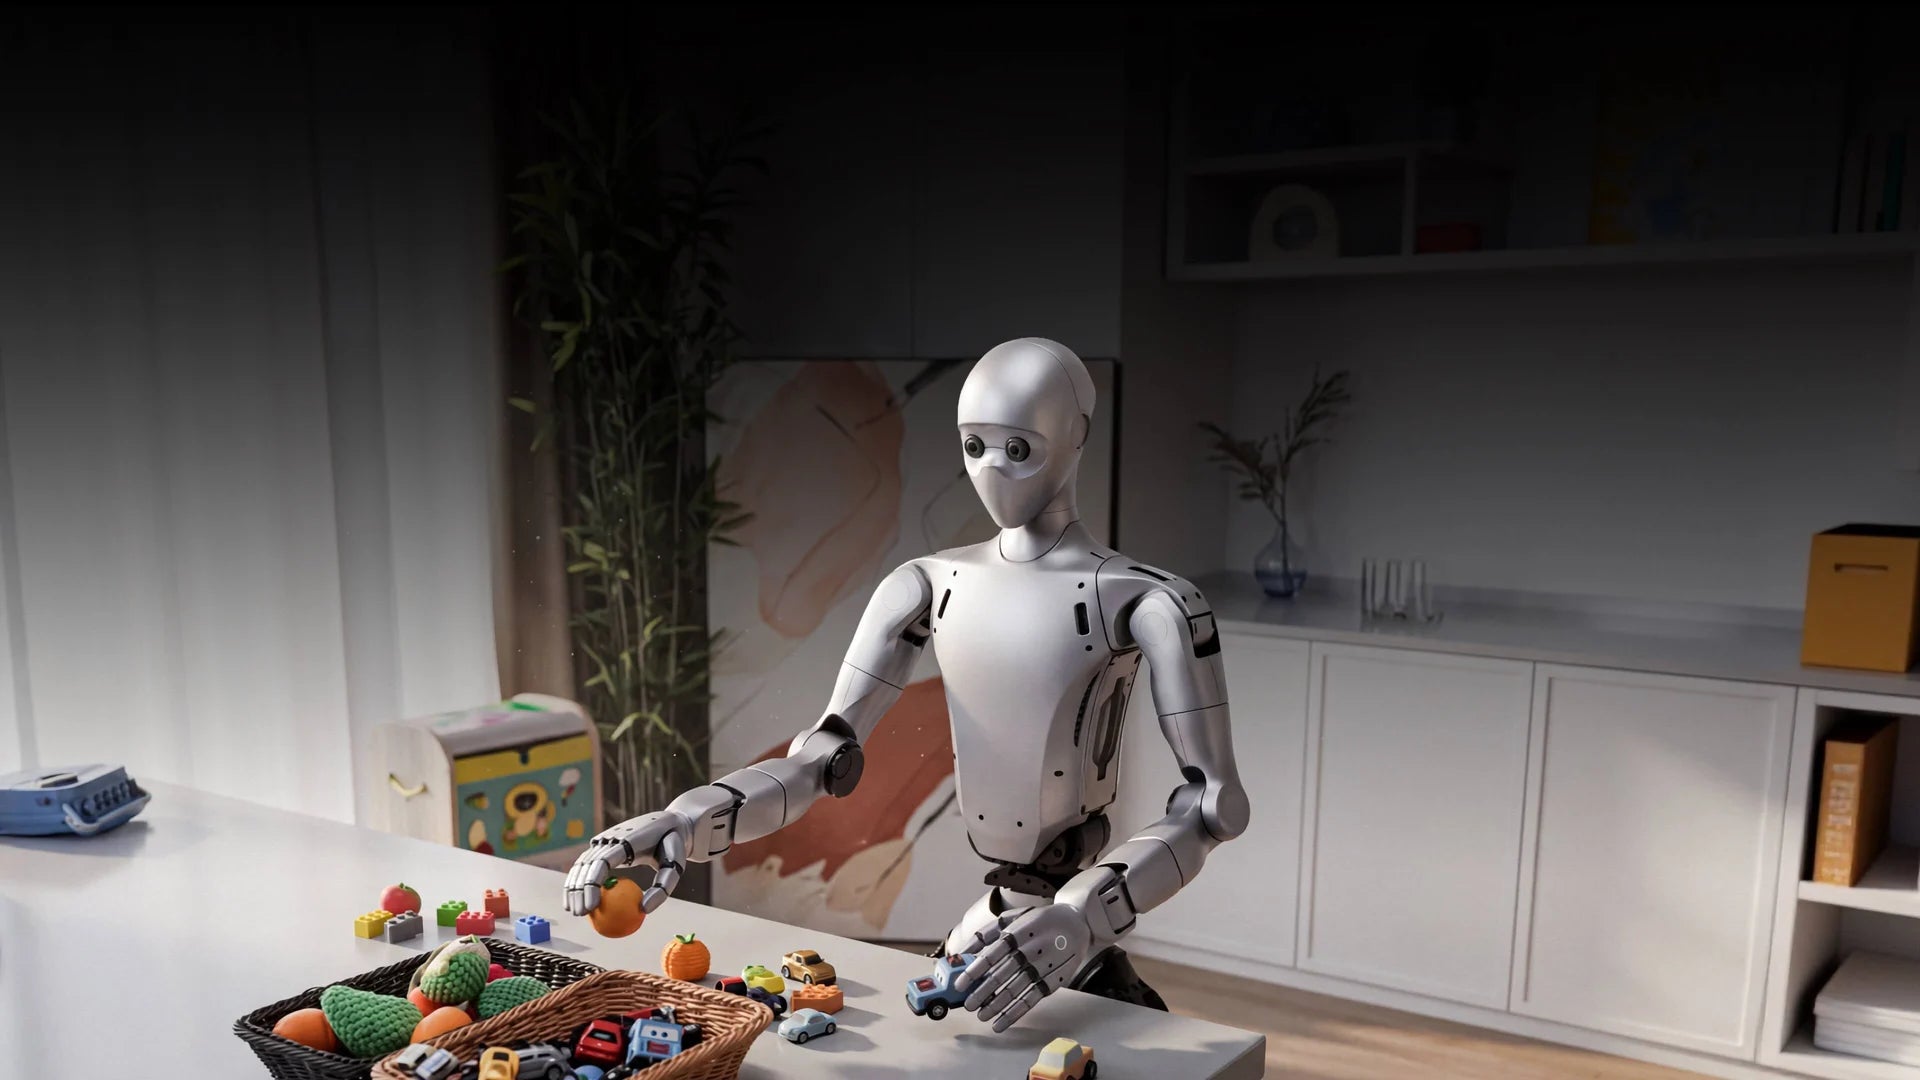
Tabletop manipulation in a research scene. It shows a setting for experiments, not housework ability.
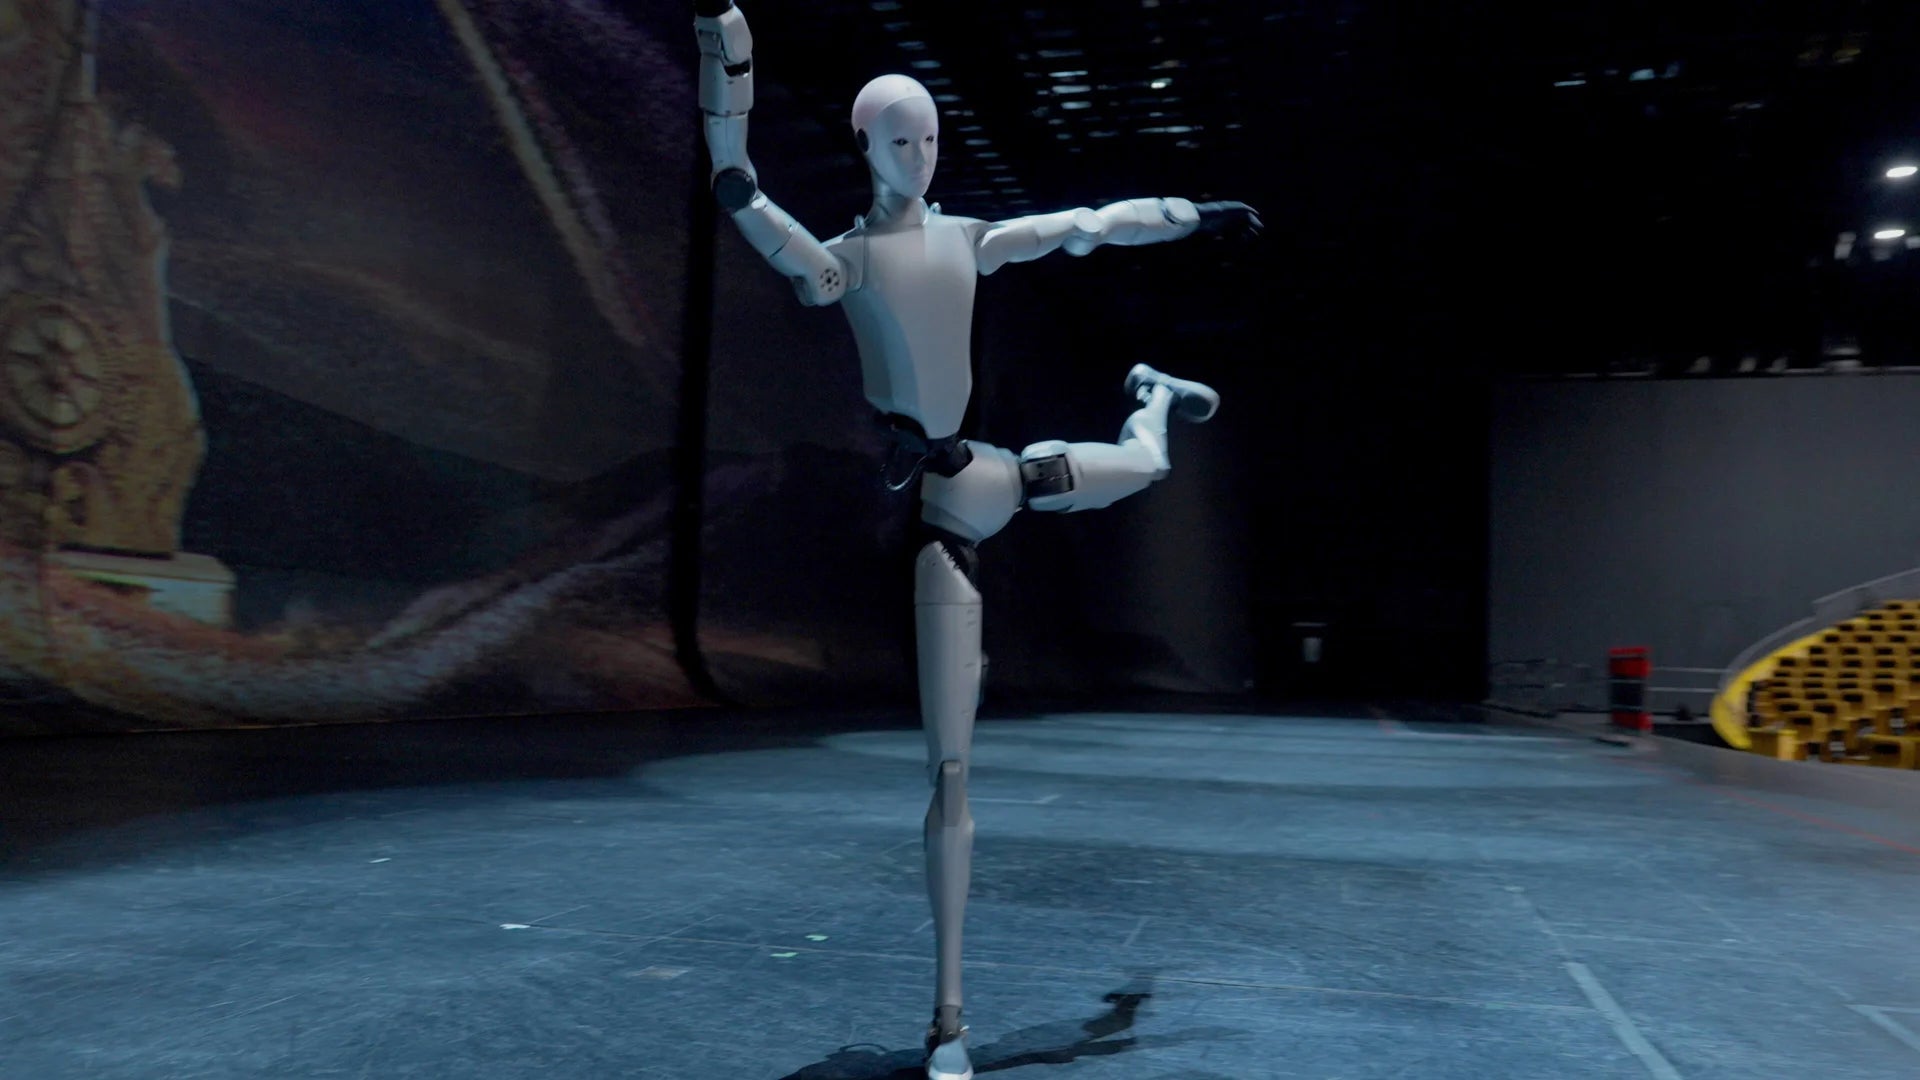
Dance and movement routines on H2. Each motion needs an action pack or policy matched to the model.
T2 end effectors. Grasping results still depend on perception, control software and testing with your objects.
Images show manufacturer demonstrations. Autonomous and teleoperated results should always be reported separately.
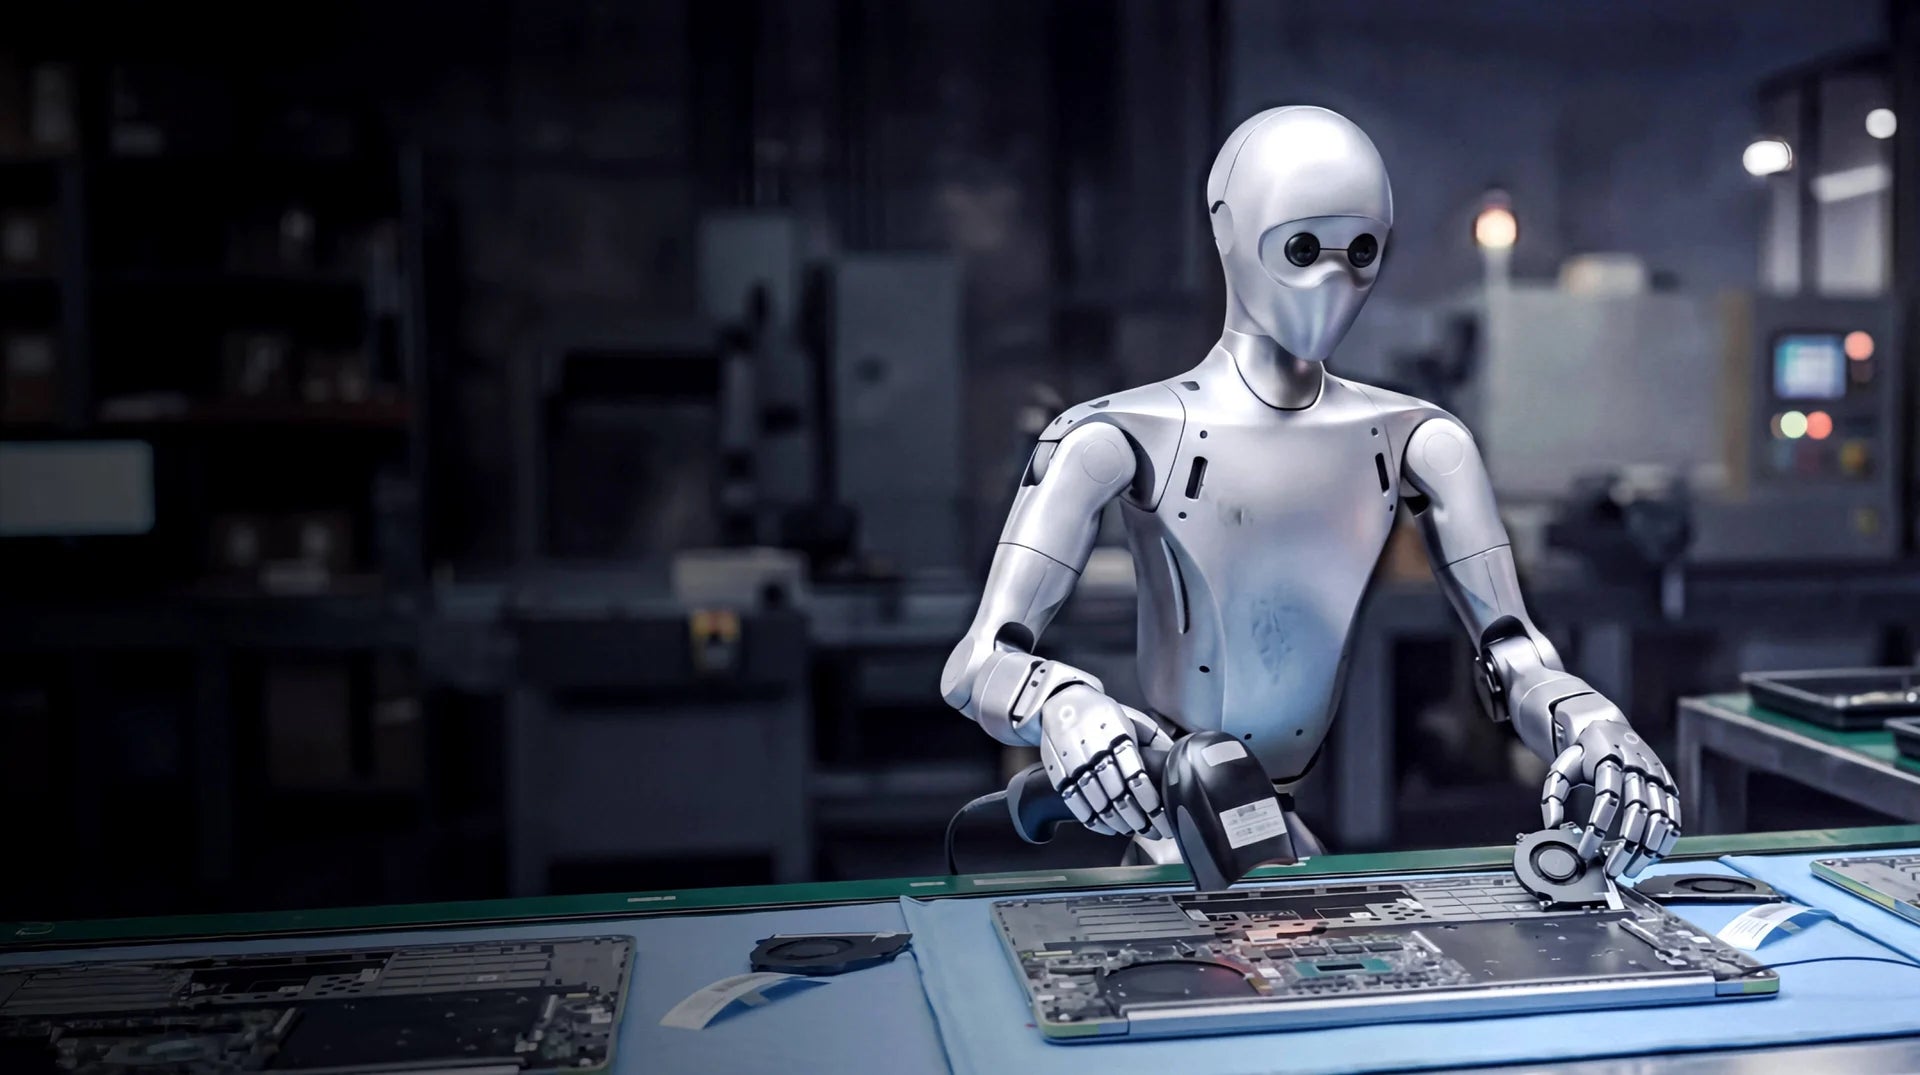
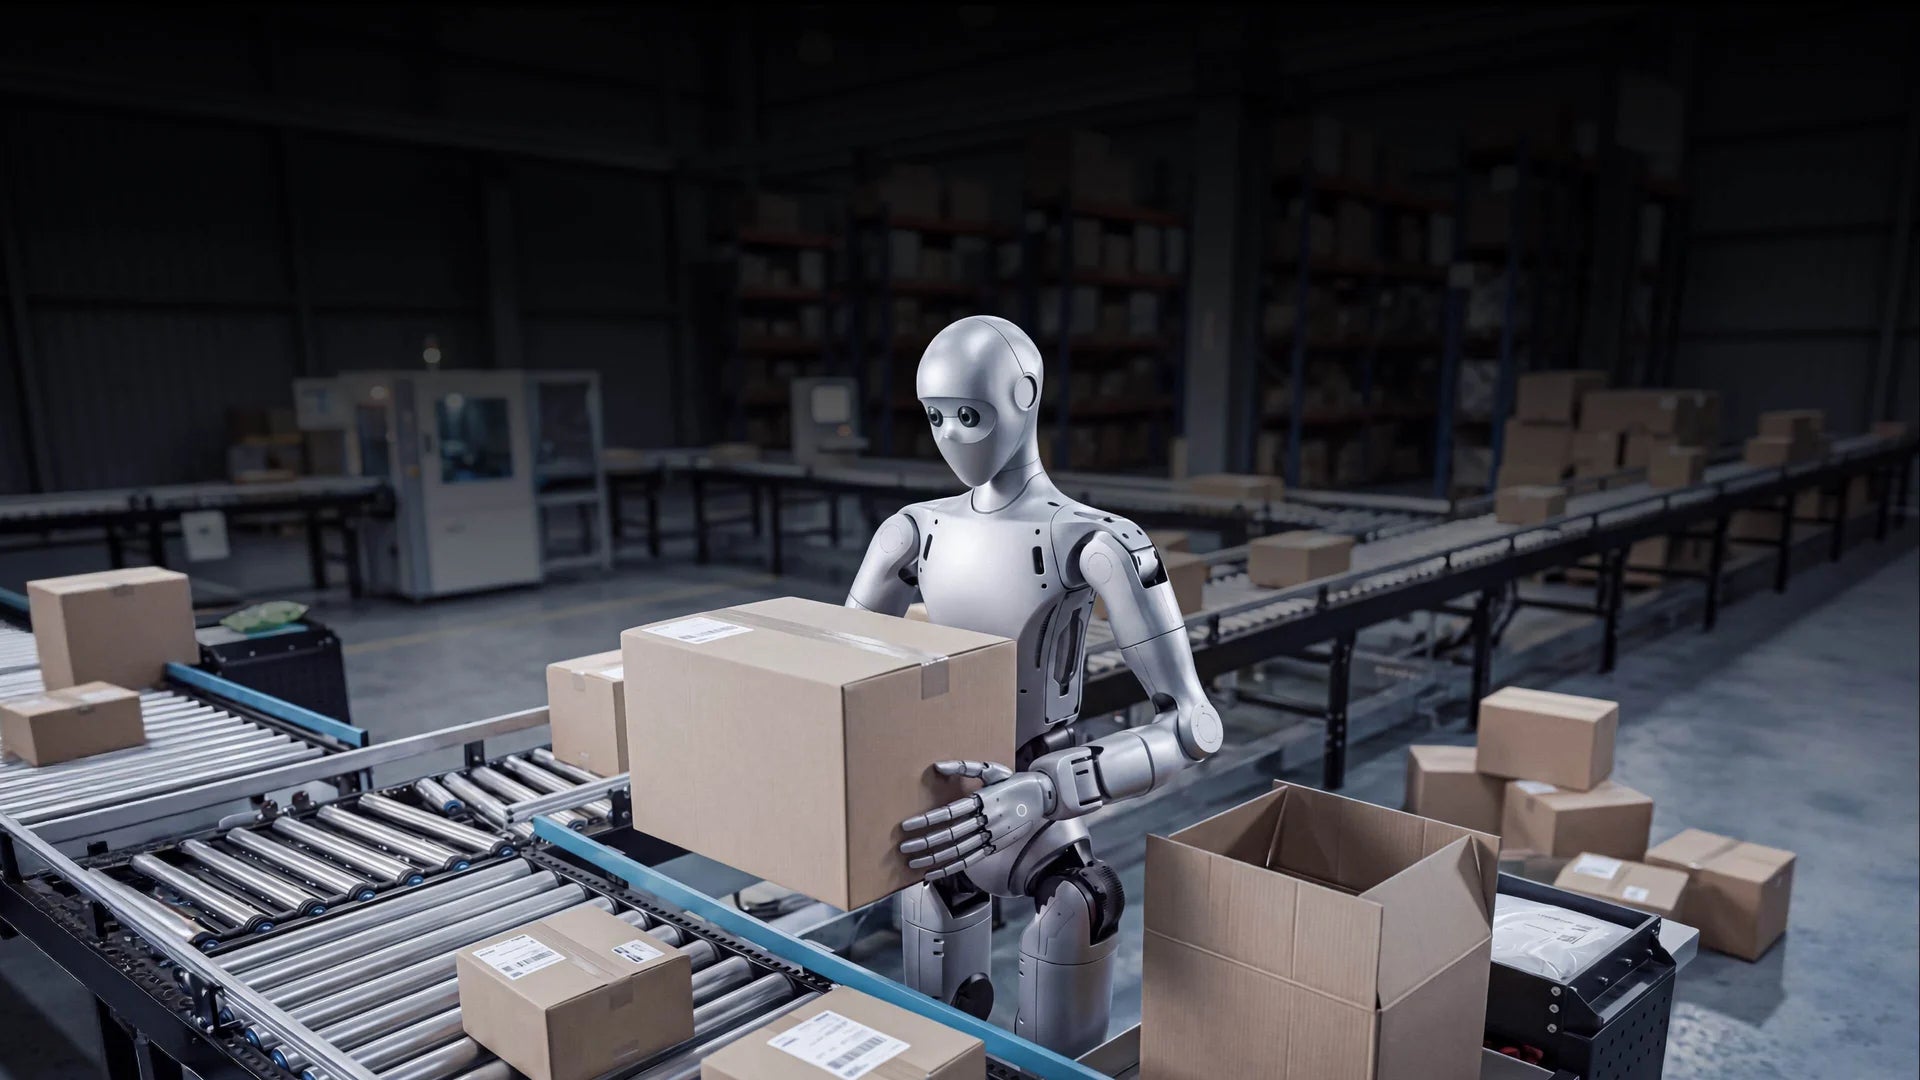
Platforms ship with interfaces and tools. Results come from your team’s work, on versions we record together.
Documented for each platform.
Edition, optional parts and software access.
Built, trained and validated by your team.
Board-level figures from the manufacturers’ tables. Units differ and cannot be compared directly.
| Processor | AI computing | Memory | |
|---|---|---|---|
| T1 Basic | Jetson AGX Orin 32GB | 200 TOPS | 32 GB |
| T1 Standard | Express-i7 (motion) + Jetson AGX Orin 32GB (perception) | 200 TOPS on the perception board | 8 GB · 32 GB, per board |
| T2 Education | High-performance ARM | 375 TOPS (INT8) | 16 GB |
| T2 Professional | Jetson Thor T5000 | 2,070 TFLOPS (FP4, sparse) | 128 GB |
| H2 Plus | Jetson T5000 | 2,070 TFLOPS (FP4, sparse) | 128 GB unified |
Training workstations, safety rigs and XR headsets are not part of the robot. We list what your project needs alongside the quote.

Share the task, your team and the systems you already use. We’ll check which platform, edition and interfaces fit, and flag anything that needs development.